Set the sequence
Each Setup Operator rolls the die and places the four cubes according to its official sequence. The referee checks both arrangements before the simultaneous start.
Two autonomous robots, four colours and one shared sorting destination.
Two teams compete at the same time on a shared field. Each robot has four coloured cubes to collect and place on the matching targets. A die sets the pickup order before every match, so the team must prepare for more than one familiar sequence.
Students have different roles: setting out the cubes, starting the autonomous robot and placing approved guidance barriers. The robot itself finds its way, handles one cube at a time and returns for the next. Teams also need to avoid conflict in the shared sorting area.
The first robot to sort all four cubes correctly wins. If time runs out, completed work and the match tie-breaks decide the result. Colour-sensor solutions can compete in this edition; verified camera-based recognition can earn a separate optional AI Vision Bonus, but it cannot overturn a valid match result.
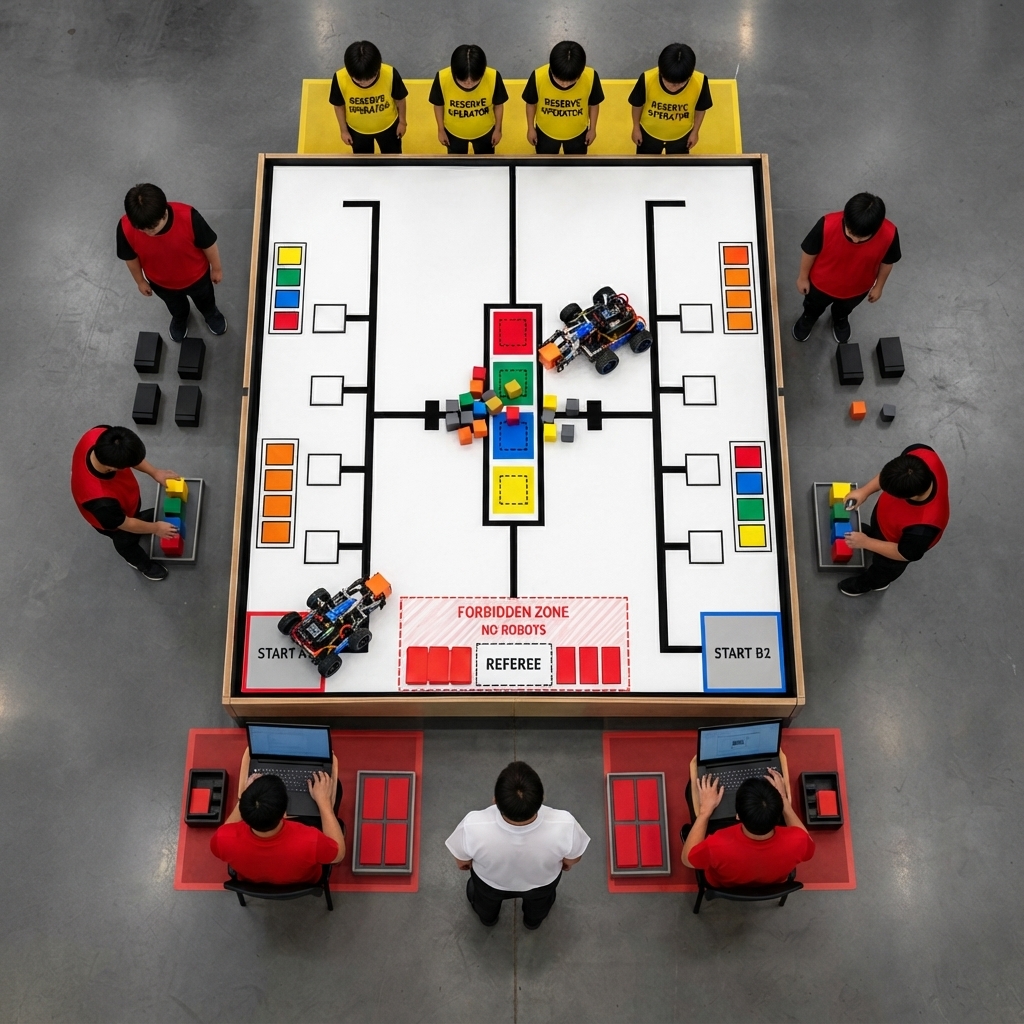
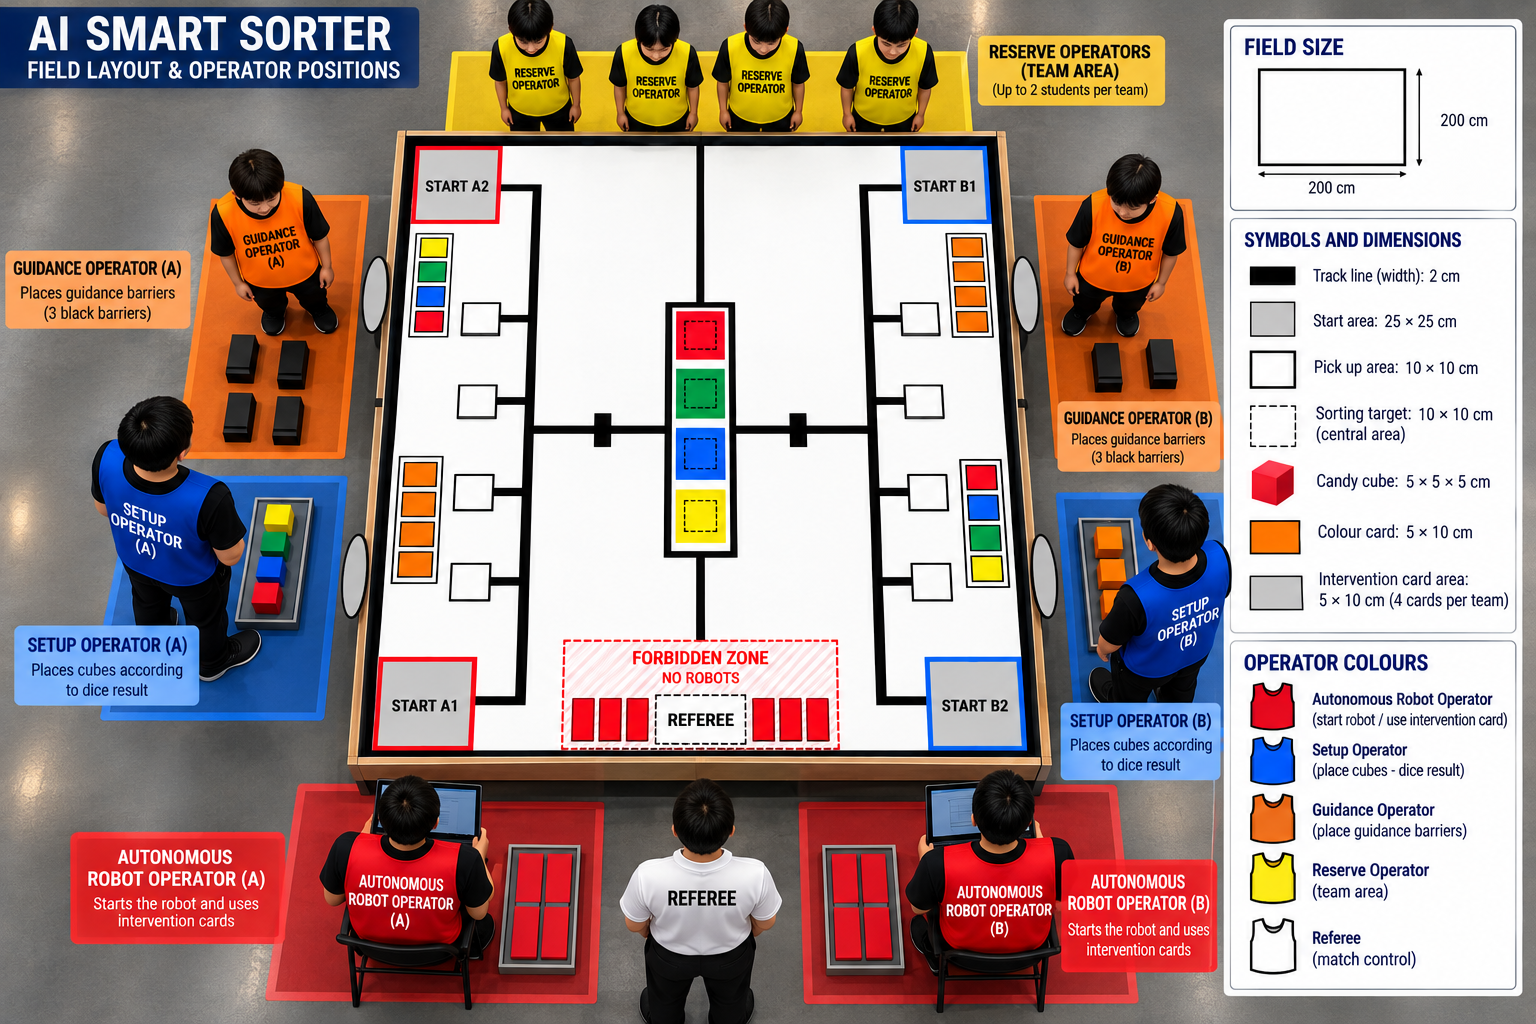
Each Setup Operator rolls the die and places the four cubes according to its official sequence. The referee checks both arrangements before the simultaneous start.
The robot navigates autonomously to a pickup branch, removes one cube and identifies its colour. Carrying or controlling a second cube at the same time does not earn credit.
Deliver to the matching target and release the cube fully inside it. Guidance Operators use only the marked barrier slots; barriers can close completed branches or temporarily hold a robot back while the shared area is occupied.
The robot returns for the next cube. A student reset needs an approved Recovery Card, and the clock keeps running. The match ends on a confirmed four-cube completion or at the time limit.
| Task | Points |
|---|---|
| Cube removed from pickup area | 5 each |
| Cube delivered to correct target | 20 each |
| All four colours completed | 20 bonus; base maximum 120 |
| Verified AI vision before manipulation | 5 per cube; optional maximum 20 |
| Group match points: win / draw / loss | 2 / 1 / 0 |
The match result is primary. At time expiry, compare sorted cubes, removed cubes, Recovery Cards, penalties and the time of the last successful delivery, in that order. Group ranking uses match points, head-to-head result, base score and then verified AI Vision Bonus. A mounted camera alone earns no bonus; recognition must be demonstrated before handling the cube.
Setup, Guidance and Autonomous Robot Operators have separate responsibilities. The Guidance Operator only places approved barriers in official slots and never moves the robot or touches cubes.
After START, remote commands, pointing the robot and unauthorised physical guidance are prohibited. A robot must not enter the opponent's private half or deliberately interfere with its robot or cubes.
Students perform competition-day programming, adjustment and repair during permitted periods. Safe platforms and sensors are open; AI vision is optional in this edition. Consult the rulebook for exact sanctions and recovery handling.
Practise every dice sequence, dependable cube release and waiting safely at the shared target area. Assign roles clearly and decide whether you can reliably demonstrate the optional vision bonus. Participation implies acceptance of the official rulebook.
Review the official competition rules, evaluation criteria, project requirements and submission guidelines before preparing your project.